Equations of motion (ရွေ့လျားမှု ညီမျှခြင်းများ)
Flight dynamics model တစ်ခု၏ core ရည်ရွယ်ချက်မှာ vehicle အပေါ် သက်ရောက်နေသော force နှင့် moment များကို ပေးထားသောအခါ၊ ကမ္ဘာ (သို့မဟုတ် ဂြိုဟ်တစ်ခုခု) ၏ surface ပေါ်မှ ပျံသန်းနေသော craft တစ်ခု၏ path ကို propagate ပြုလုပ်ပြီး track လိုက်ရန် ဖြစ်ပါသည်။ ကျွန်ုပ်တို့သည် လေယာဉ်၏ characteristic များကို သိရှိထားပြီး၊ ဂြိုဟ် (gravity, rotation rate စသည်) ၏ characteristic များကိုလည်း သိရှိထားပါသည်။ Reader သည် moving reference frame များ ပါဝင်သော rigid body dynamics ကို ကျွမ်းကျင်ထားပြီးသားဟု မျှော်လင့်ထားပါသည်။ သို့သော်လည်း၊ ဤအချက်အလက်အားလုံးကို flight simulator တစ်ခုထဲတွင် စုစည်းတည်ဆောက်ခြင်းသည် ဒုနှင့်ဒေးဖြစ်ပြီး ပင်ပန်းစေနိုင်ပါသည်။
ဤအပိုင်းတွင် JSBSim က ပေးအပ်ထားသော quaternion, matrix, vector, နှင့် location math class များကို အသုံးပြု၍ JSBSim::FGPropagate တွင် implement ပြုလုပ်ထားသည့်အတိုင်း aerospace vehicle equations of motion ကို ဆွေးနွေးထားပါသည်။ Rigid body equations of motion နှင့် ဆက်စပ်သော အောက်ပါအပိုင်းများတွင် ဖော်ပြထားသော equation အများစုကို JSBSim software ၏ အဓိက formulation reference ဟု ယူဆထားသော (Stevens:Lewis:Johnson:2015) စာအုပ်မှ ကိုးကားထားပါသည်။
ဤ reference manual တွင် အသုံးပြုထားသော notation သည် Stevens နှင့် Lewis အသုံးပြုသည့်အတိုင်း ဖြစ်ပါသည်-
-
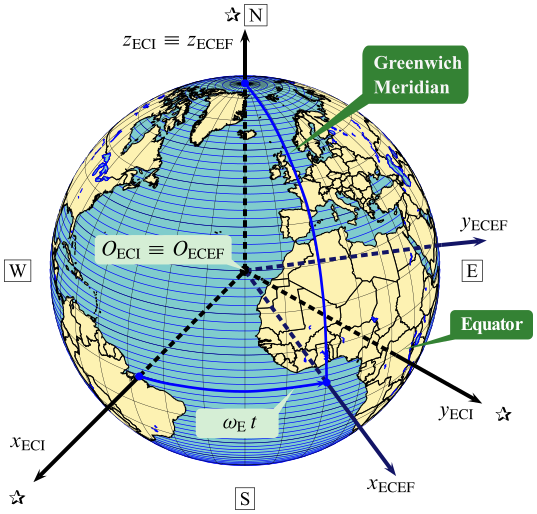
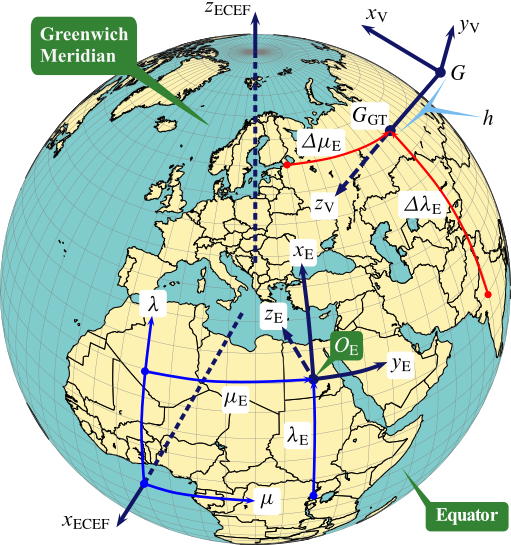
Lower right subscript၊ ဥပမာအားဖြင့် \(\boldsymbol{v}_\mathrm{CM/e}\) သည် parameter ၏ object သို့မဟုတ် frame ဆက်နွယ်မှုကို ဖော်ပြပါသည်။ ပေးထားသော ဥပမာတွင်၊ \(\boldsymbol{v}_\mathrm{CM/e}\) သည် ECEF frame နှင့် ဆက်စပ်သော CM (center of mass) ၏ velocity ကို ရည်ညွှန်းပါသည်။
-
Upper right superscript၊ ဥပမာအားဖြင့် \(\boldsymbol{v}^\mathrm{b}\) သည် coordinate system တစ်ခုကို ရည်ညွှန်းပါသည်။ ဆိုလိုသည်မှာ motion ကို မည်သည့် coordinate system တွင် ဖော်ပြထားသည်ကို ဖော်ပြပါသည်။
-
Left superscript သည် derivative တစ်ခု ယူထားသော frame ကို သတ်မှတ်ပေးပါသည်။
ဆက်လက် ဖြည့်စွက်ရန်
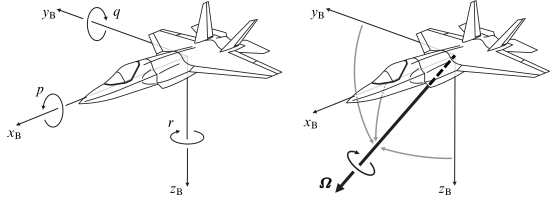
လေယာဉ် angular velocity vector \(\boldsymbol{\Omega}\) နှင့် body axis \((p,q,r)\) ရှိ angular speed component များ။
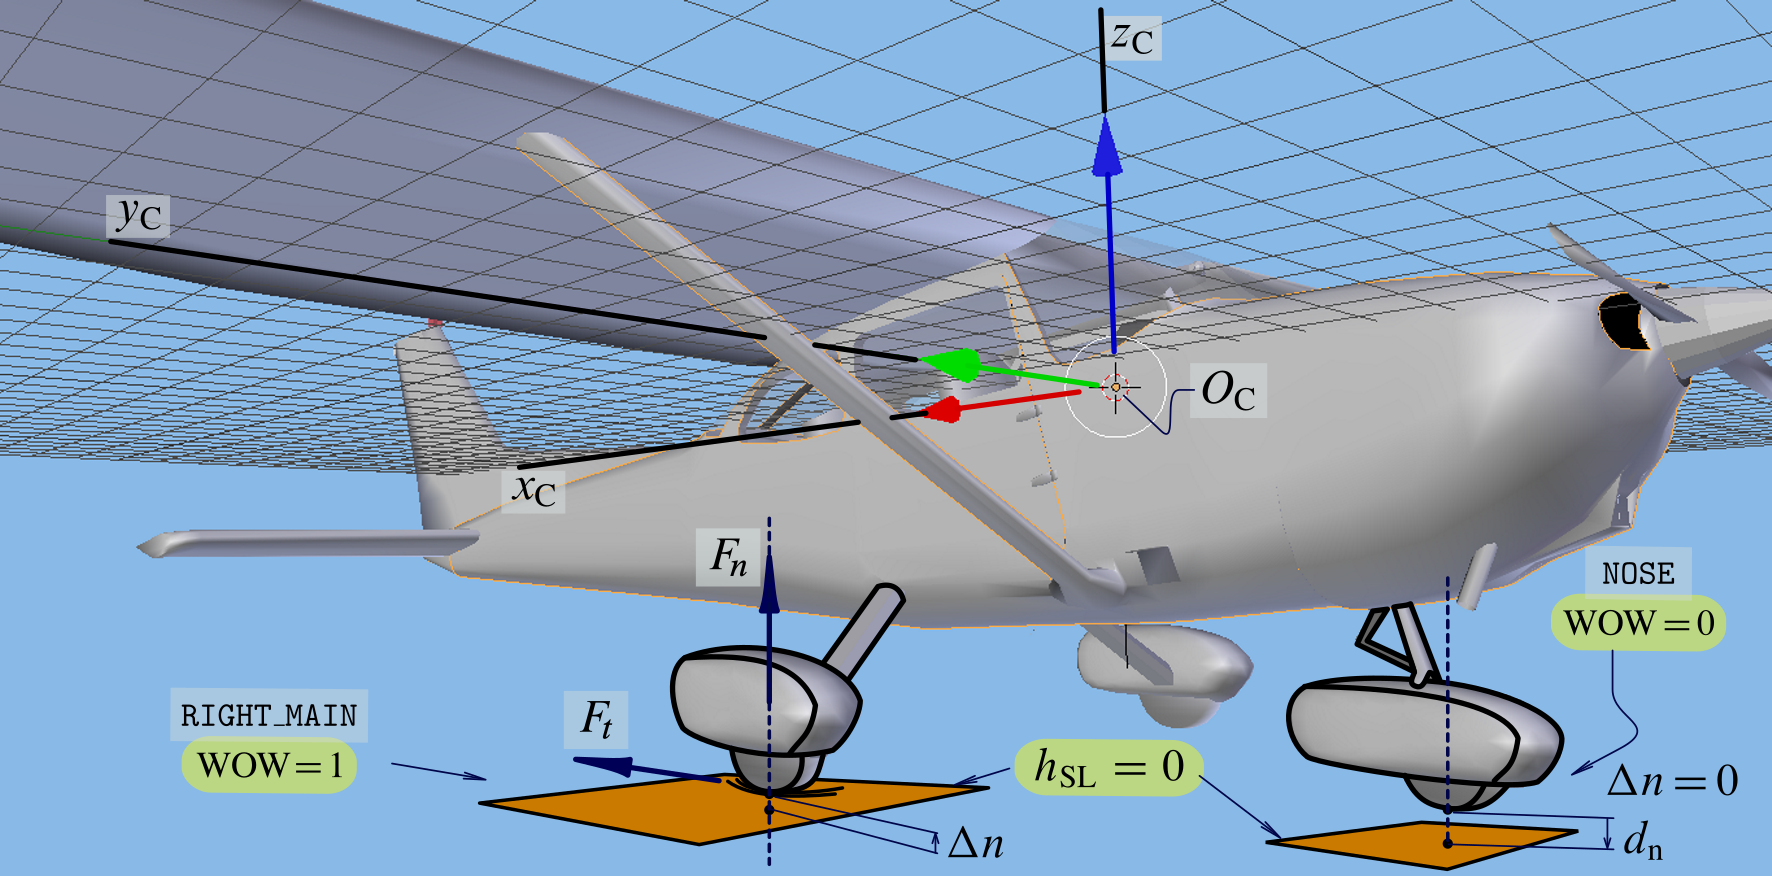
Ground reaction model။ Main gear ၏ right wheel အတွက် \(\mathrm{WOW} = 1\) နှင့် nose wheel အတွက် \(\mathrm{WOW} = 0\) ဖြစ်နေသော ground contact အခြေအနေတစ်ခု။